Uncooperative objects
Inspect and navigate around spacecraft and debris that cannot cooperate.
Penumbra Autonomy builds onboard perception, estimation and navigation that let spacecraft see, characterize and operate around uncooperative objects, without waiting on the ground.
Our capabilities
Perception, estimation and navigation for inspection and proximity operations around uncooperative objects.
Maintain awareness of an object as it moves through light and shadow. Our perception capabilities support inspection of targets that offer no cooperative assistance.
A clearer view of the object your mission depends on.
Build an understanding of an object's behavior and its state relative to the observing spacecraft, informing inspection and approach decisions.
More knowledge before committing to closer operations.
Provide relative navigation around uncooperative objects, supporting spacecraft operations as conditions change and reducing reliance on continuous ground involvement.
Greater autonomy for operations around unfamiliar targets.
Designed for spacecraft with tight size, weight, power, and cost constraints.
Accessible autonomy across spacecraft and fleets.
The Problem
Inspect and navigate around spacecraft and debris that cannot cooperate.
Operate onboard when ground communications are unavailable.
Characterize unfamiliar objects before closer operations.
Mission applications
Capabilities for commercial and national-security missions that need to understand and operate around objects in orbit.
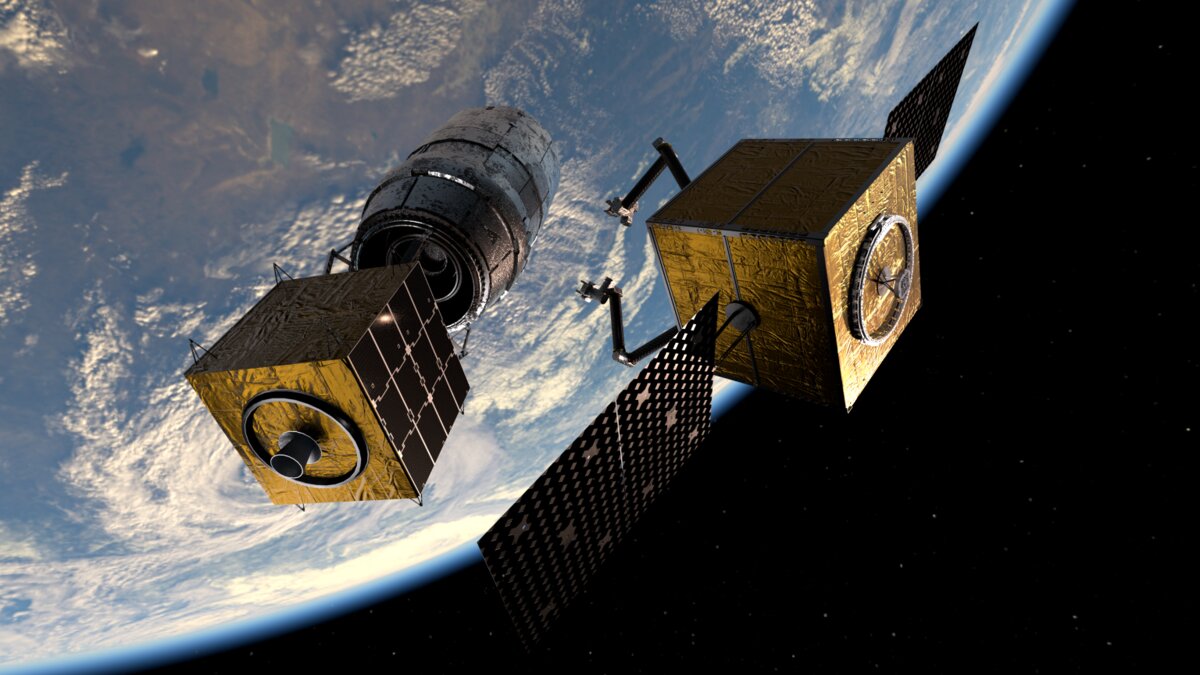 Sustainable space operations
Assess a client or inactive spacecraft before planning a closer interaction. Onboard inspection and characterization can inform servicing, mission extension, and debris-removal operations.
Discuss an inspection mission Space domain awareness
Characterize unfamiliar objects and their motion to inform operational planning. Explore onboard autonomy for missions where continuous ground involvement is impractical.
Discuss your operational needsOur team
A team shaped at Georgia Tech, bringing together experience in spacecraft autonomy, perception, and estimation.
Spacecraft autonomy
PhD candidate at Georgia Tech, researching autonomy for orbital operations.
Perception systems
PhD candidate at Georgia Tech, researching reliable perception in space.
Aerospace & autonomy
Georgia Tech faculty with expertise in control, robotics, and spacecraft autonomy.
Let's talk about your mission
Planning a mission that needs onboard inspection, characterization, or relative navigation? Let's discuss your requirements and explore the fit.